Tutorials
Runnable notebooks covering the library end to end. Open them in Colab from the badge at the top of each page.
Beginner
The scene tutorial reads a ScanNet scan, which requires accepting the ScanNet terms of use.
-
Quickstart: classify a point cloud
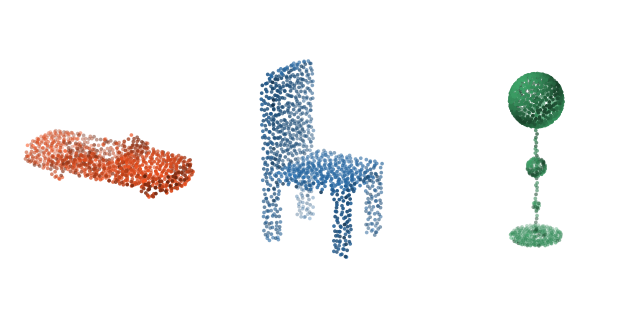
Load a pretrained model, build a transform pipeline, and classify an object in a few lines.
-
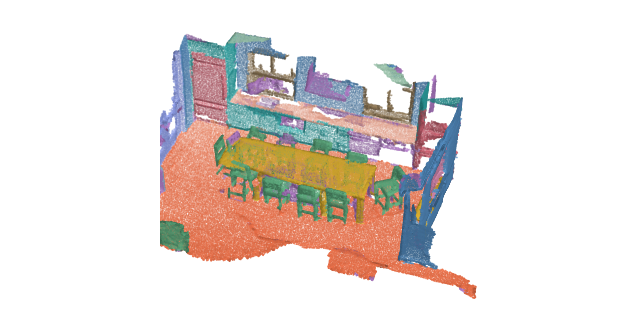
Run per-point semantic segmentation on a full indoor scene with a tiling inferer.
-
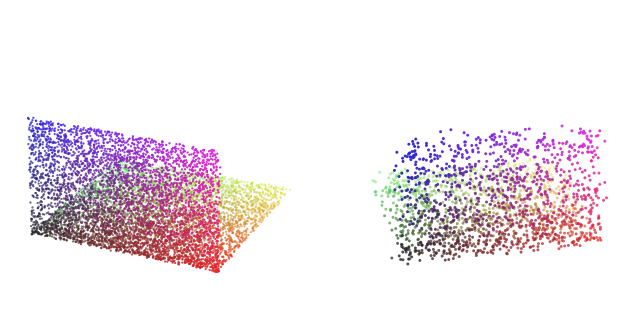
Compose dict transforms for sampling, normalization, and augmentation, and inspect each step.
Intermediate
Your own data and a plain PyTorch training loop.
-
Wrap your own point cloud files in a
Dataset, attach a transform, and collate them into packed batches. -
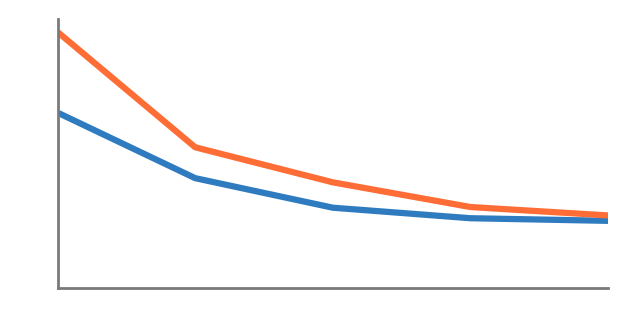
Train a classification model from scratch: dataloaders, optimizer, and the evaluation loop.
-
Features and similarity search
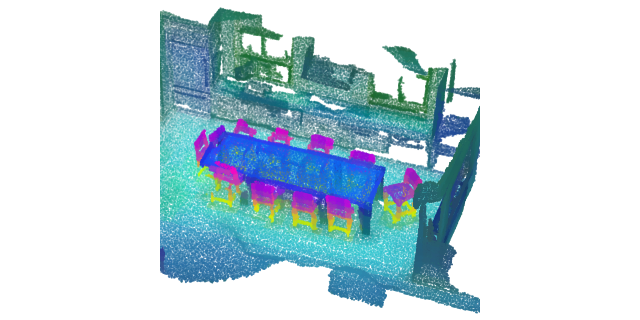
Read a frozen encoder's features, query one point, and retrieve whole shapes by descriptor.
Advanced
3D object detection on driving LiDAR.
-
Detect objects in driving LiDAR
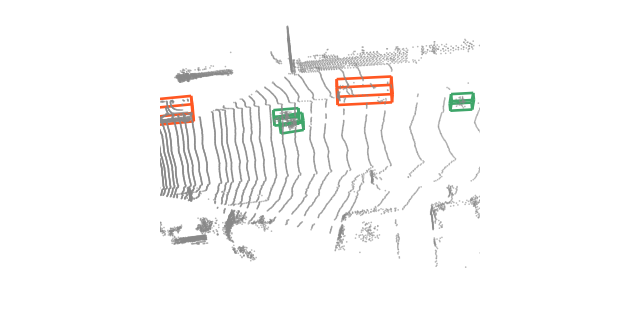
Turn one sweep into oriented 3D boxes: voxel encoding, decoding, non-maximum suppression.